Endovascular Surgical Robot Platform (stEVE)

Mar 1, 2026 · 1 min read
stEVE: Simulated EndoVascular Environment with SOFA FEM and DSA rendering
miracle-techlink / GitHub stEVE 平台代码仓库 GitHub Blog: VLA 如何落地医疗机器人 miracle-techlink.github.io · 综述文章 Link

A complete research platform for AI-assisted endovascular intervention, spanning preoperative 3D planning through intraoperative RL-guided navigation.

Pipeline:

  1. CTA → STL — TotalSegmentator vessel segmentation, VMTK centerline extraction
  2. SOFA FEM Simulation — Cosserat beam guidewire model, realistic vascular deformation
  3. RL Navigation — SAC/PPO agents with geodesic distance reward + safety constraints
  4. Biplane DSA — DLT triangulation + Beer-Lambert X-ray projection for 2D-3D registration
  5. Intraoperative Correction — SE(3) IRC-RL with real DSA feedback

Ongoing research: Training a diffusion-based trajectory planner on large-scale SOFA-generated synthetic data, transferring to real vascular geometries — targeting to overcome clinical data scarcity.

Affiliations: Tongji University × PKU DLIB | 2026


System Architecture

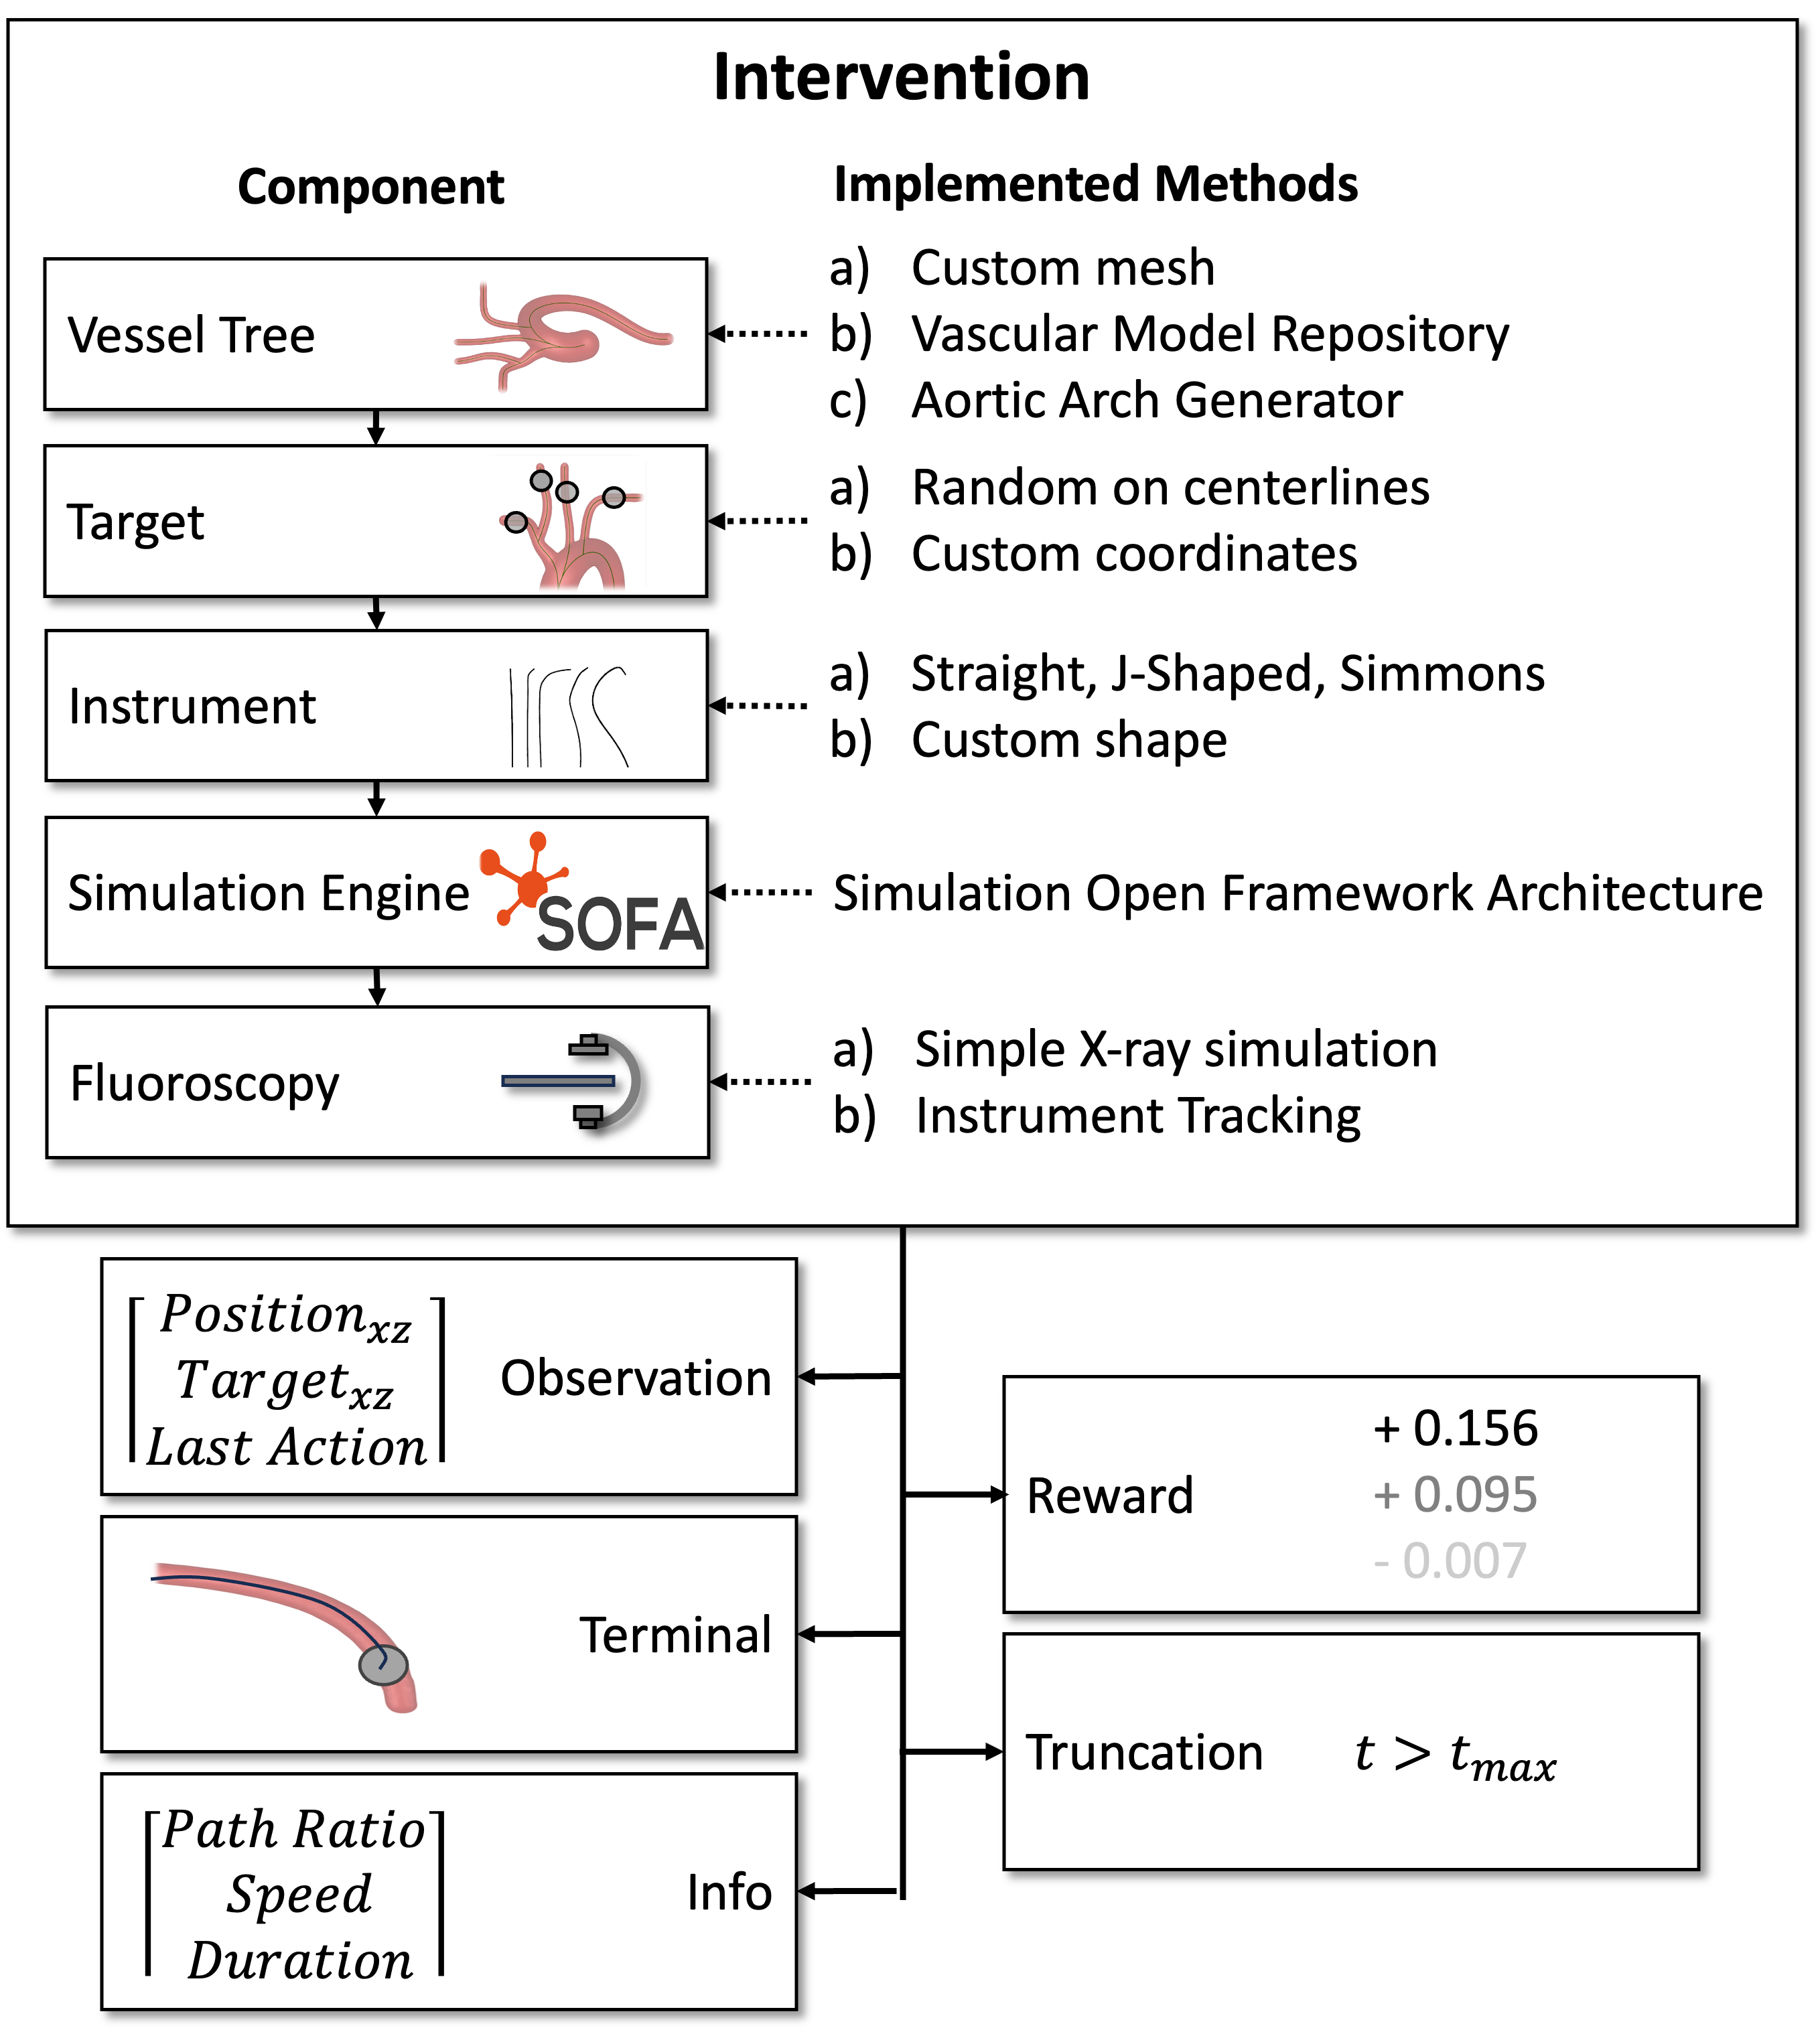
stEVE simulation pipeline: vessel tree, instrument, SOFA engine, and fluoroscopy rendering.

stEVE simulation pipeline: vessel tree, instrument, SOFA engine, and fluoroscopy rendering.

Clinical Navigation Demo

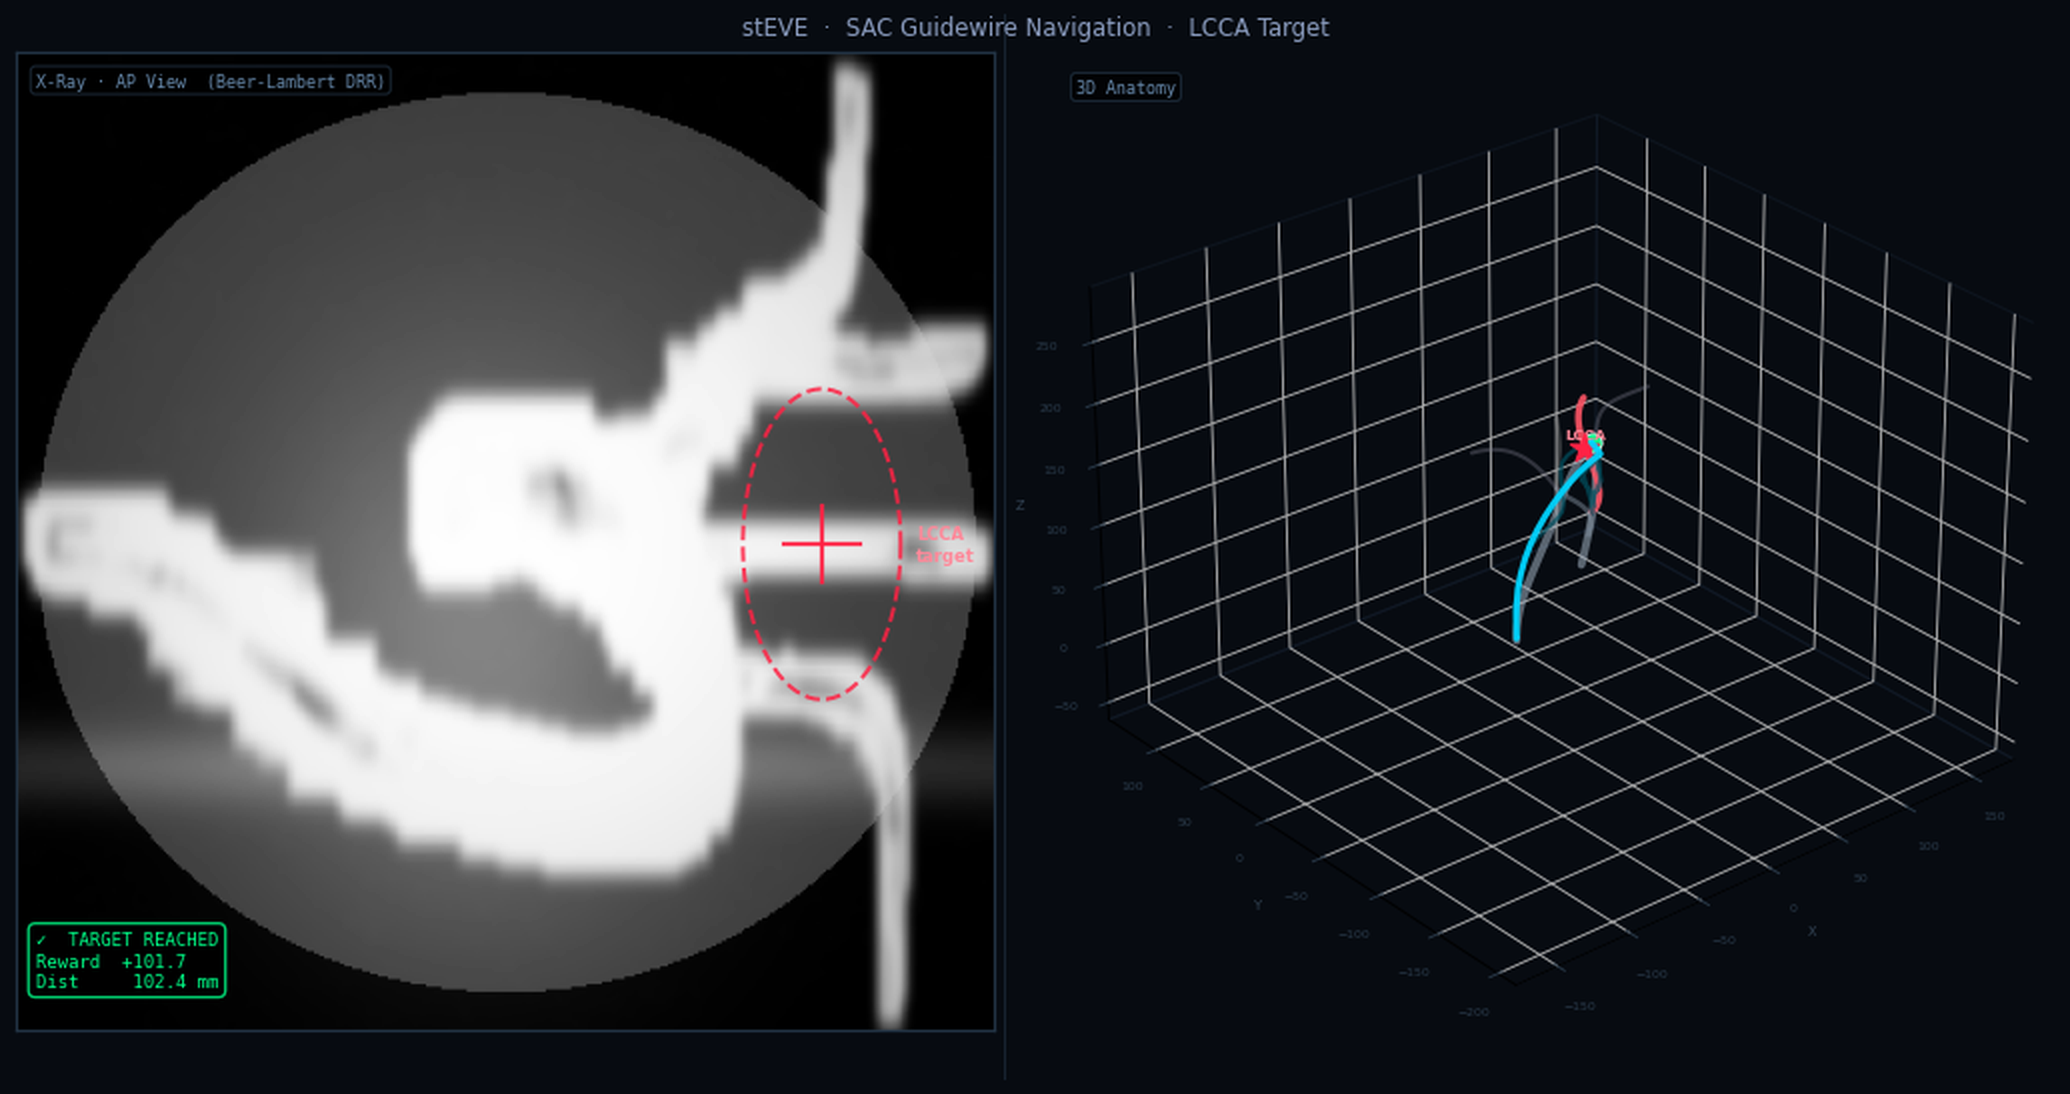
Catheter navigation in patient-specific vascular anatomy — final frame of a clinical test episode.
Catheter navigation in patient-specific vascular anatomy — final frame of a clinical test episode.