Smart Car Design — Provincial Competition Silver Award (Team Lead)
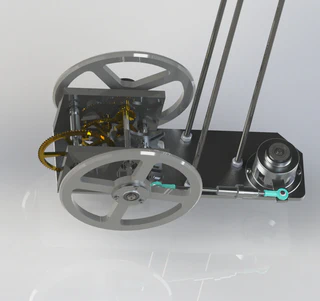 SolidWorks detailed render — cam steering mechanism with drive wheels and onboard camera
Led a team in designing and manufacturing a cam-steered autonomous smart car for the provincial-level competition, taking the project from concept through mechanical design, simulation, and hardware implementation.
Role: Team Lead — responsible for overall mechanical architecture, steering system design, trajectory modeling, and circuit design.
Mechanical Design
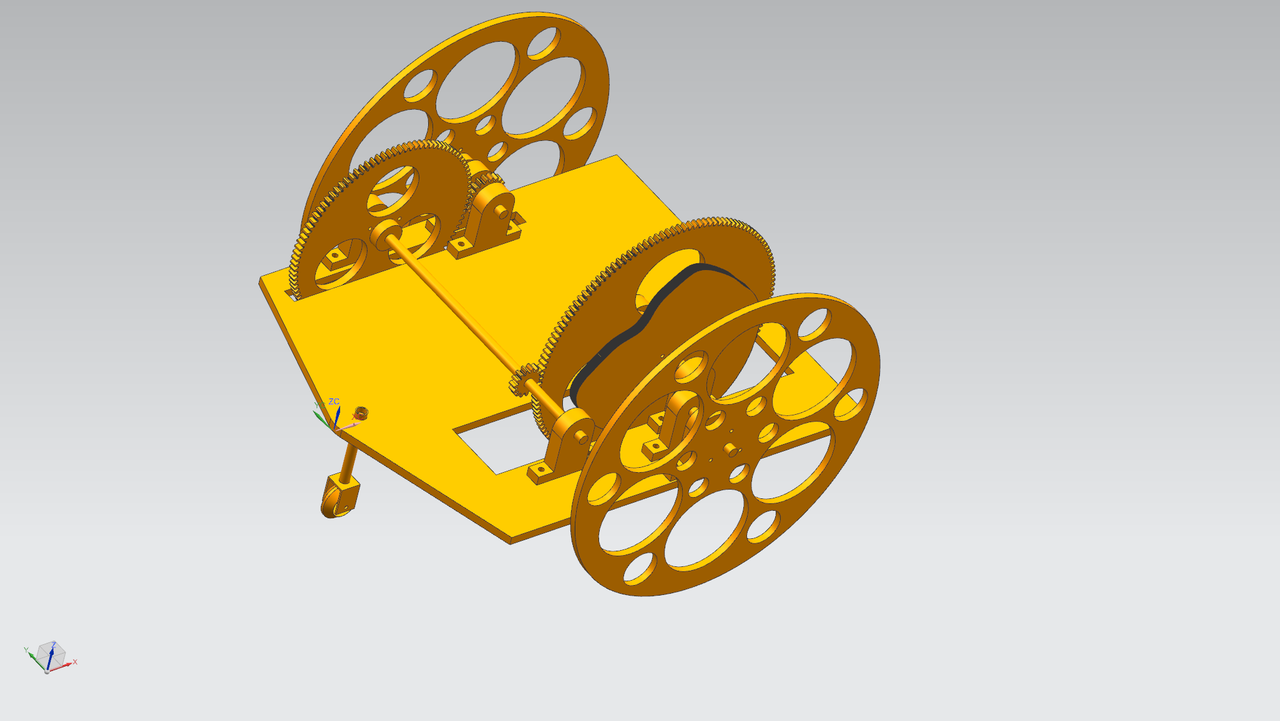
Early-stage CAD concept model — initial chassis layout and wheel configuration.
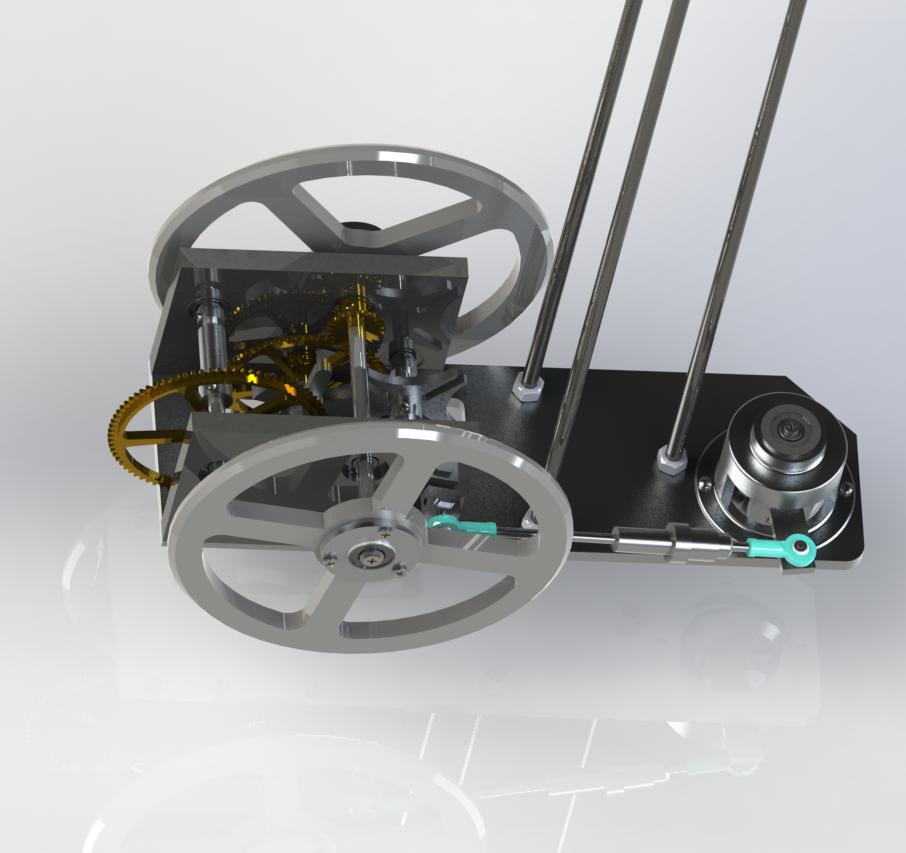
Final SolidWorks detailed render — cam steering mechanism, gear transmission, drive wheels, and onboard camera mount.
The steering system uses a cam-based mechanism to convert rotational motion into precise lateral displacement, eliminating the need for servo actuators and improving mechanical reliability. The drivetrain uses a gear reduction stage paired with brushed DC motors.
Trajectory Simulation
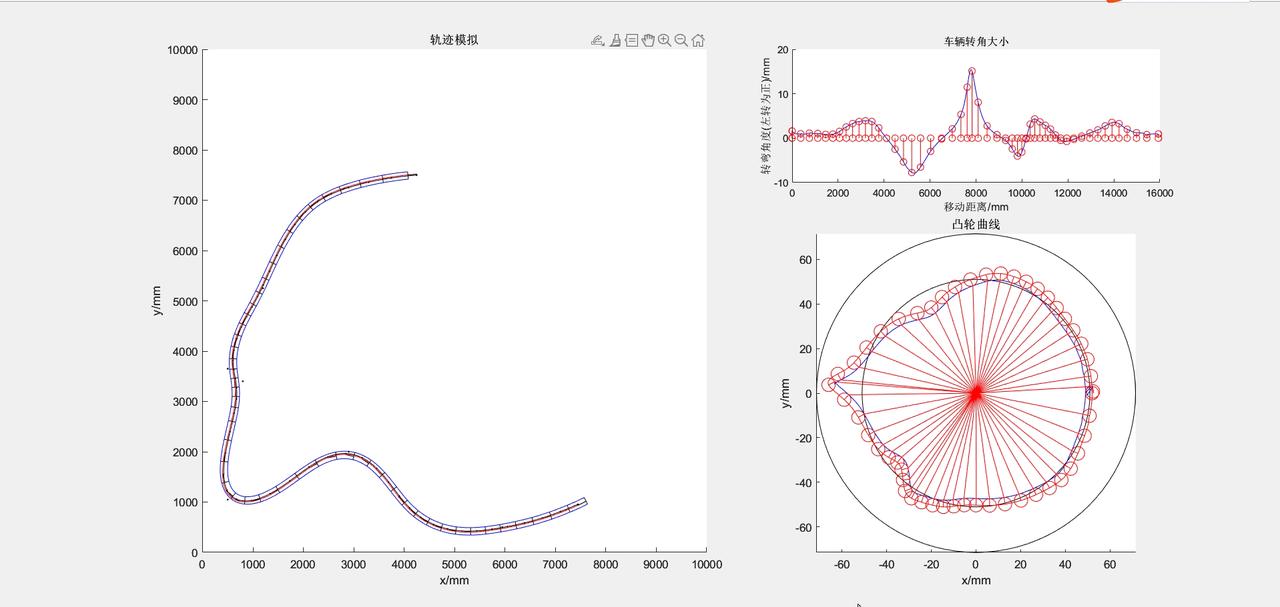
MATLAB trajectory simulation — left: full path trace (x/y in mm); top-right: vehicle turning angle vs. displacement; bottom-right: cam curve profile.
Developed a MATLAB model to simulate the vehicle trajectory based on the cam profile. Key outputs:
- Path trace — verifies the car follows the intended curved route
- Turning angle curve — validates smooth, continuous steering input
- Cam profile — designed for minimal acceleration jerk and stable contact force
Charging Circuit
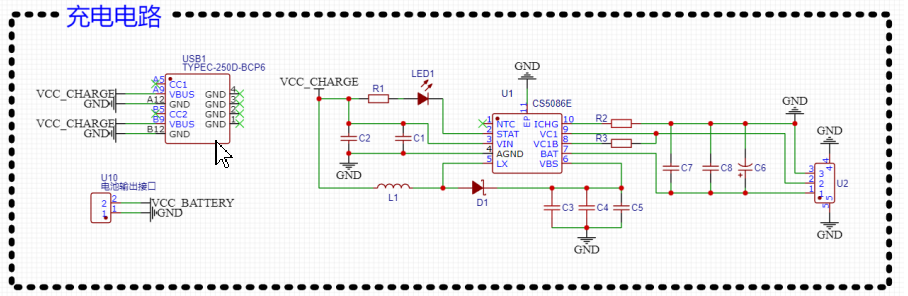
Custom charging circuit schematic — onboard battery management for the competition vehicle.
Designed a custom charging circuit with battery management to ensure reliable power delivery during competition runs.
Award: Silver Award, Provincial Smart Car Competition | Team Lead Stack: SolidWorks · MATLAB · PCB Design · DC Motor Control
