Robotic Arm Simulation Engine — Tongji × Siemens Industry 4.0 Lab
Feb 1, 2024
·
1 min read
 Three.js real-time robotic arm visualization with slider parameter control
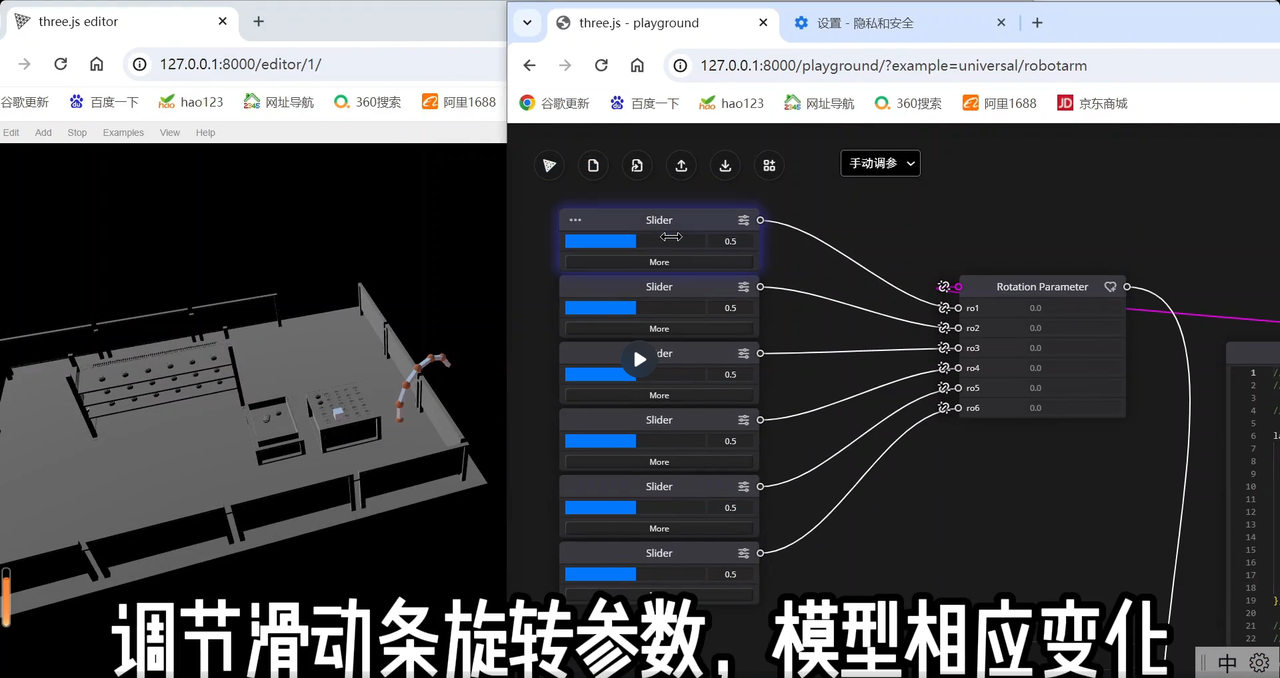
Three.js real-time robotic arm visualization — adjusting slider parameters updates the 3D model in real time.
A joint research project between Tongji University’s Sino-German Industry 4.0 Lab and Siemens, replacing legacy particle swarm optimization (PSO) with deep reinforcement learning for higher-precision robotic arm control.
Technical work:
- DQN agent for joint trajectory optimization, replacing PSO baseline
- Three.js 3D visualization — interactive slider-based parameter control, real-time model updates, importable industrial equipment scenes
- SITP project certification completed
Key insight: After exposure to NVIDIA Isaac Sim, identified that the core need is not model import/visualization but custom algorithm interfaces and GPU-accelerated physics simulation — pivoted research direction accordingly.
Affiliations: Tongji University Sino-German Industry 4.0 Lab × Siemens | 2023.11 – 2024.02
