Open-Source Robotics Collaboration with 子豪兄
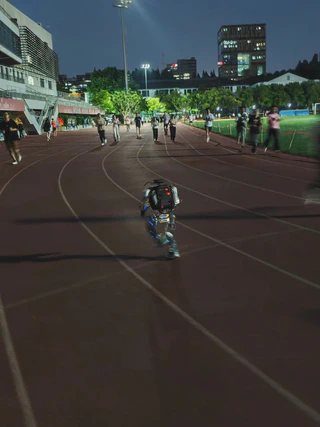 OpenDuckMini running on Tongji University track at night
A series of open-source robotics projects co-built with 子豪兄 — Tongji University’s most prominent AI/robotics education creator — focused on making embodied AI hardware accessible to the community.
OpenDuckMini — Bipedal Duck Robot
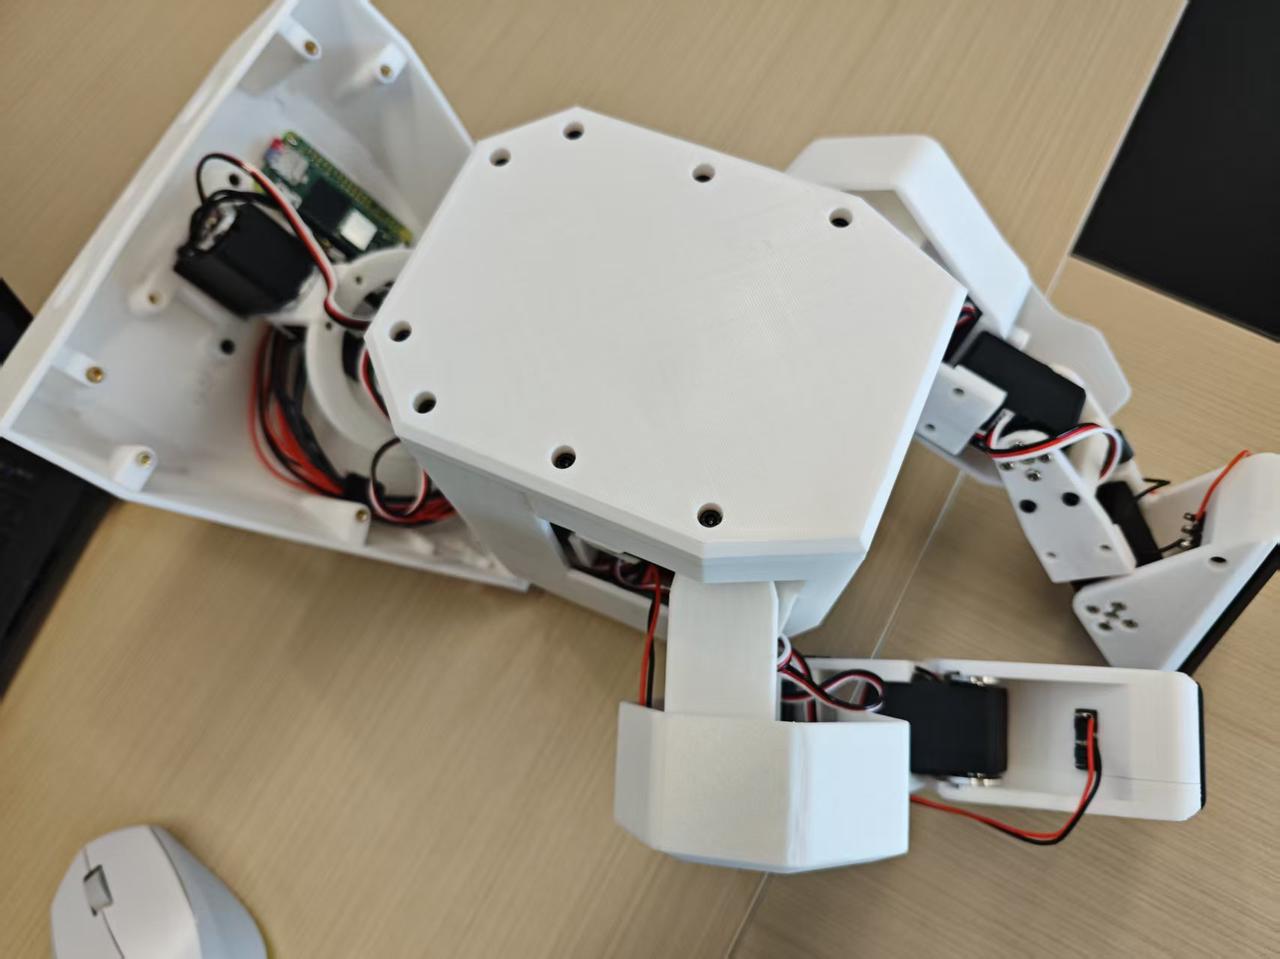
Hardware internals: 3D-printed PLA/PETG frame, servo actuators at each joint, Raspberry Pi onboard compute, custom PCB wiring harness.
- Dynamic walking and running gait — field-tested on Tongji University track
- 3D-printed structural components (PLA/PETG), servo-actuated joints, Raspberry Pi compute
Quadruped Platform
Four-legged robot platform for reinforcement learning locomotion experiments and sim-to-real transfer research, built alongside the bipedal work as part of the same hardware studio.
Community & Mission
All projects are fully open-source and documented — reproducible by anyone with access to a 3D printer and basic electronics. The goal is to democratize embodied AI hardware and accelerate the research-to-product cycle for students and researchers across China.
