LeRobot & Embodied AI Hackathon Projects
Oct 1, 2025
·
1 min read
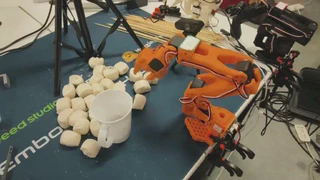 LeRobot hardware — servo-actuated robot arm platform
LeRobot — Study & Deployment
Deep dive into Hugging Face LeRobot — the leading open-source embodied intelligence framework — covering architecture analysis, training pipeline reproduction, and real-robot deployment.
Study scope:
- ACT (Action Chunking with Transformers) policy architecture
- Diffusion Policy training and inference pipeline
- TDMPC world-model-based control
- Real-robot deployment on SO-100 / Koch v1.1 hardware
LeRobot 中文社区文档 架构解析 · 训练流程 · 真机部署 · HuggingFace 官方收录 Feishu Docs📖 Co-authored comprehensive Chinese-language documentation. Officially featured by Hugging Face.
Connection to research: LeRobot’s flow-matching policy backbone directly informed the GDN-Memory integration work — understanding the inference pipeline was prerequisite to designing sub-1ms memory update scheduling.
tri.me — Home-Care Robot Platform
🏆 3rd Place — 小红书巅峰赛 Hackathon
tri.me 家庭护理机器人 Demo Tri.me吹了吗家庭护理机器人 · 小红书巅峰赛三等奖 小红书 persuer0/treame 松灵 Nero 七自由度机械臂 · 刷牙 / 吹头发 / 剃胡子 GitHub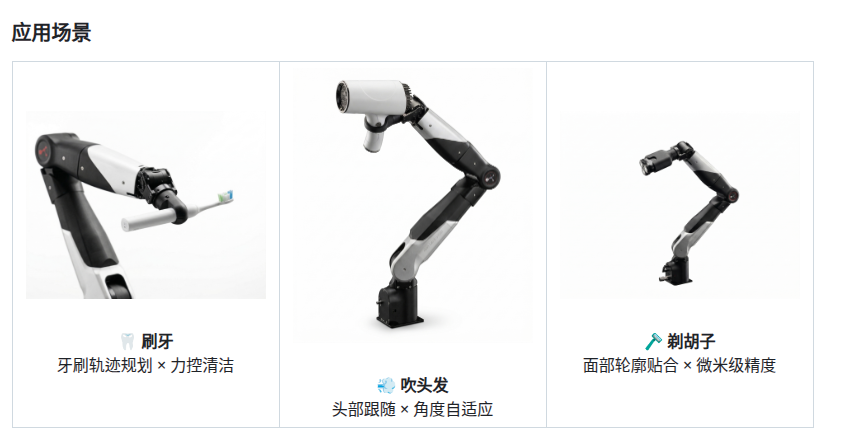
三类护理场景:刷牙 × 吹头发 × 剃胡子
| 场景 | 技术要点 |
|---|---|
| 🦷 刷牙 | 牙刷轨迹规划 × 力控清洁 |
| 💨 吹头发 | 头部跟随 × 角度自适应 |
| 🪒 剃胡子 | 面部轮廓贴合 × 微米级精度 |
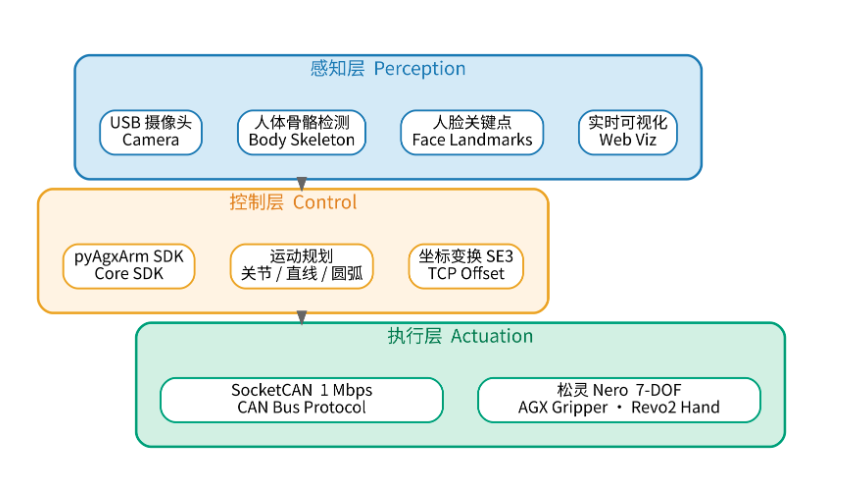
三层解耦系统架构:感知层 / 控制层 / 执行层
三层解耦架构:
- 感知层 — 人体骨骼/人脸关键点实时检测,摄像头硬件加速编解码
- 控制层 — 机械臂 SDK,支持关节空间、笛卡尔、直线、圆弧多种运动模式,内置 SE3 坐标变换
- 执行层 — SocketCAN 协议驱动松灵 Nero,实现真正"以人为中心"的护理闭环
